Xynova Flex 2 Dexterous Robot Hand
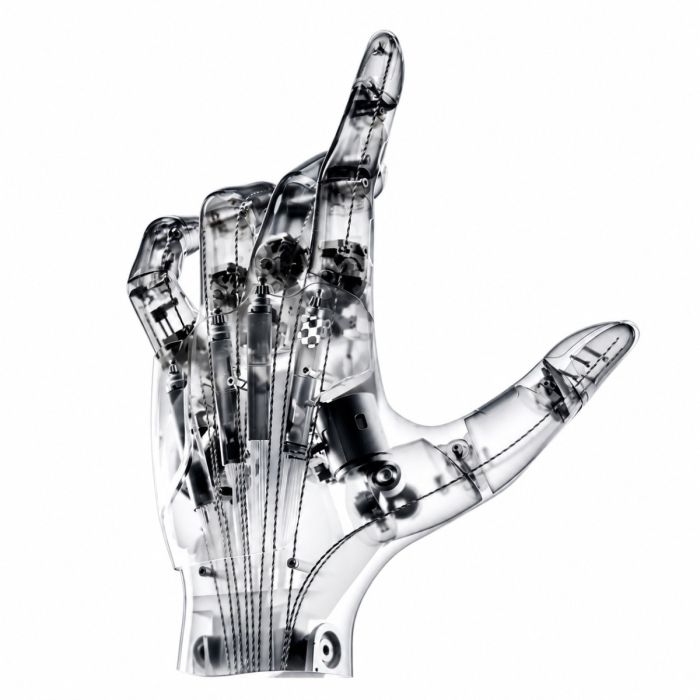
The Xynova Flex 2 is a 23 degree of freedom bionic robot hand that combines tendon and direct drive actuation in a package of about 400 g. Micro linear actuators provide a 12 kg single hand grasp load, while back drivable joints, slip detection and a replaceable soft skin support durable, compliant manipulation in factories, service robots and humanoid platforms.
In stock
- BRAND:
- XYNOVA
- MODEL:
- FLEX 2
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- ALLOW 6-8 WEEKS FOR DELIVERY
- SKU:
- Xynova-Flex-2
Xynova Flex 2 Dexterous Robot Hand
Robot hand designers usually have to choose between two compromises. Tendon-driven hands can be slender and lifelike, but they are often soft where stiffness is needed. Direct-drive hands are firm and responsive, but they tend to grow bulky and heavy at the wrist. The Xynova Flex 2 Dexterous Robot Hand does not settle for either. It combines tendon ropes and direct motor drive in one human-scale hand, so that the fingers can be both delicate and decisive. The result is a hand that can feel its way around an unfamiliar object and still hold a heavy one securely.
Robots Middle East supplies the Xynova Flex 2 Dexterous Robot Hand to research institutes, universities, humanoid robot developers and system integrators across the Middle East. We prepare each quotation for the project concerned. Robots Middle East also coordinates delivery to your site and remains your point of contact for technical questions after the hand arrives.
Background
Xynova Technology and the humanoid supply chain
The hand is made by Xynova Technology Co., Ltd., a supplier of core components for humanoid robots. Companies of this kind sit one level below the robot makers. They develop the joints, actuators and end effectors from which complete humanoid platforms are assembled. A component supplier lives or dies by how easily its parts integrate into other people's machines. That is reflected in the Flex 2's open development ecosystem, which supports customisation, expansion and integration rather than tying the hand to a single host platform.
A hybrid drive in a bionic frame
The key technology of the Flex 2 is its hybrid drive, which combines tendon rope with direct motor drive and is powered by micro linear actuators. Xynova has built the hand to full dimensional bionics: its size, joints and kinematic structure follow the human hand. It has 23 degrees of freedom, of which 19 are active and 4 are passive. The passive joints let the fingers settle naturally around an object, while the active joints carry out deliberate motion. The thumb achieves a perfect score in the Kapandji Thumb Opposition Test. This is the clinical assessment of how far a thumb can reach across the fingers and palm, and the score reflects free extension movements and close shape adaptation. Sensing is handled by multi-modal perception fusion together with a human-like "cerebellum". This reflex layer provides adaptive grasping, slip detection and compliant reflexes.
Technical Specifications
| Specification | Value |
|---|---|
| Degrees of freedom | 23-DOF bionic configuration (19 active, 4 passive) |
| Weight | 400g |
| Fist extension speed | 2 fist extensions per second |
| Repeatability | ±0.1mm |
| Force control accuracy | Down to 0.05N |
| Single-hand grasp load | 12kg |
| Rated continuous operation load | 4kg |
| Actuators | Micro linear actuators |
| Drive type | Hybrid drive of tendon rope and direct motor drive |
| Control | Back-drivable under load for hybrid force/position control |
| Thumb opposition | Perfect score in Kapandji Thumb Opposition Test |
| Perception | Multi-modal perception fusion with human-like "cerebellum" for adaptive grasping, slip detection and compliant reflexes |
| Skin and safety | Soft replaceable skin, anti-pinch seams |
| Palm surface | Wear- and puncture-resistant |
| Durability | Dustproof, dropproof and impact-resistant; anti-creep tendon ropes; full-range temperature control |
| Cycle life | Millions of open/close cycles |
| Development | Open development ecosystem for customisation, expansion and integration |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
Xynova has not published the dimensions, power supply voltage, communication protocol, fingertip force per finger, operating temperature range, IP rating, sensor count and sampling rate, or the contents of the box; these are confirmed at quotation.
Why does the Xynova Flex 2 combine tendon rope and direct motor drive?
The two drive methods have complementary strengths. Routing tendons through the fingers allows the actuators to sit away from the joints. This keeps the fingers slim and human-proportioned, and it helps a hand reach a low weight. The Flex 2 weighs 400g. Direct motor drive offers a stiffer, more immediate link between actuator and joint. That suits fast, precise motion, such as two fist extensions per second, and the ±0.1mm repeatability the hand achieves.
Combining the two lets the hand use each method where it serves best. Tendons can stretch over time, which is a common weakness of tendon-driven hands. Xynova counters this with anti-creep tendon ropes and full-range temperature control, which together ensure stable operation. The hand is also back-drivable under load. An external force can therefore move the fingers, and the controller can sense and respond to that movement. This is the basis for hybrid force/position control and for force control accuracy down to 0.05N.
What is the difference between the grasp load and the rated continuous load?
The Flex 2 carries two load figures, and they answer different questions. The single-hand grasp load of 12kg describes what the hand can hold. The rated continuous operation load of 4kg describes what it handles during sustained work. When planning a task cycle, the continuous figure is the one to design around. The higher figure indicates the reserve available for short peaks, such as lifting a heavier object briefly or resisting a sudden pull. If your application handles loads close to either figure, we recommend raising this with us when you request a quotation, so that the duty cycle can be reviewed for your task.
Who is the Xynova Flex 2 Dexterous Robot Hand for?
The first group is humanoid robot developers. They need an end effector whose size and kinematics match the human hand, so that the robot can use tools and spaces designed for people. The full dimensional bionics of the Flex 2 and its Kapandji-rated thumb are aimed directly at that requirement.
The second group is research laboratories working on manipulation, grasp planning and tactile learning. For them, the open development ecosystem, slip detection and compliant reflexes provide a platform for experiments rather than a closed product.
Industrial and service integrators form a third group. Their tasks call for a hand that can switch between gentle and firm handling. The soft replaceable skin, anti-pinch seams and wear-resistant palm help with safety and maintenance in shared workspaces.
Universities building teaching programmes in robotics and mechatronics may also find value in a hand that illustrates bionic design, hybrid drives and force control in one device. If you are comparing several end effectors before you decide, our Robot Hands category gathers the options we supply.
What is the Xynova Flex 2 Dexterous Robot Hand used for?
- Humanoid robot development — fitting a human-proportioned hand to bipedal and torso platforms that must work in environments built for people.
- Dexterous manipulation research — studying in-hand manipulation, grasp synthesis and finger coordination across many degrees of freedom.
- Tactile and slip-detection studies — using the multi-modal perception and reflex layer to investigate how robots react before an object falls.
- Force-controlled handling — picking up fragile or deformable items where fine force control matters more than raw strength.
- Teleoperation and imitation learning — mirroring a human operator's hand movements with a hand of matching kinematics, to collect demonstration data.
- Teaching and demonstration — showing students how bionic structure, hybrid drives and compliant control work together in a single device.
Pricing and Availability
Robots Middle East supplies the Xynova Flex 2 Dexterous Robot Hand on a quotation basis. This allows us to confirm the configuration and the integration details for your project. Delivery, customs clearance and technical support are arranged together with the quotation. Please tell us about your host robot, your intended tasks and any interface requirements, and we will respond with a tailored offer. A quotation can be requested through the form available on this page.
Frequently Asked Questions
How many degrees of freedom does the Xynova Flex 2 have?
The hand has 23 degrees of freedom in a bionic configuration. Of these, 19 are active and 4 are passive.
How heavy is the hand, and how much can it hold?
It weighs 400g. Its single-hand grasp load is 12kg, and its rated continuous operation load is 4kg.
How precise is the Xynova Flex 2?
The hand has a repeatability of ±0.1mm. Its force control accuracy reaches down to 0.05N, supported by back-drivable hybrid force/position control.
Can the hand detect an object slipping?
Yes. Multi-modal perception fusion and a human-like "cerebellum" provide slip detection, adaptive grasping and compliant reflexes.
How durable is the hand in daily use?
The hand is dustproof, dropproof and impact-resistant, with a wear- and puncture-resistant palm surface. It is built for millions of open/close cycles, and its skin is soft and replaceable.
Can I integrate the hand with my own robot or software?
The Flex 2 has an open development ecosystem that supports customisation, expansion and integration. Robots Middle East will discuss your host platform and interface requirements as part of your quotation.
Where can I buy the Xynova Flex 2 Dexterous Robot Hand and what does it cost?
You can obtain it from Robots Middle East, which supplies it across the Middle East. The cost depends on your configuration and project, so we provide it in a personal quotation that you can request on this page.
Summary
The Xynova Flex 2 Dexterous Robot Hand is designed to avoid the usual trade-off between lifelike tendons and firm direct drive. Its hybrid of tendon rope and direct motor drive, powered by micro linear actuators, sits inside a human-scale bionic frame with 23 degrees of freedom. This pairing gives the hand a perfect Kapandji thumb score, a weight of 400g and repeatability of ±0.1mm. It can also hold 12kg in a single grasp. Perception fusion, slip detection and compliant reflexes help it react to what it is holding. The replaceable skin, anti-pinch seams and robust construction keep it serviceable in the laboratory and on the workshop floor. Robots Middle East quotes, delivers and supports the hand throughout the region. For developers, researchers and integrators who want a hand that is both gentle and strong, this page is the starting point.