Xynova PR21-100-140-HS Rotary Actuator
In stock
- BRAND:
- XYNOVA
- MODEL:
- PR21-100-140-HS
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-PR21-100-140-HS
Xynova PR21-100-140-HS Rotary Actuator
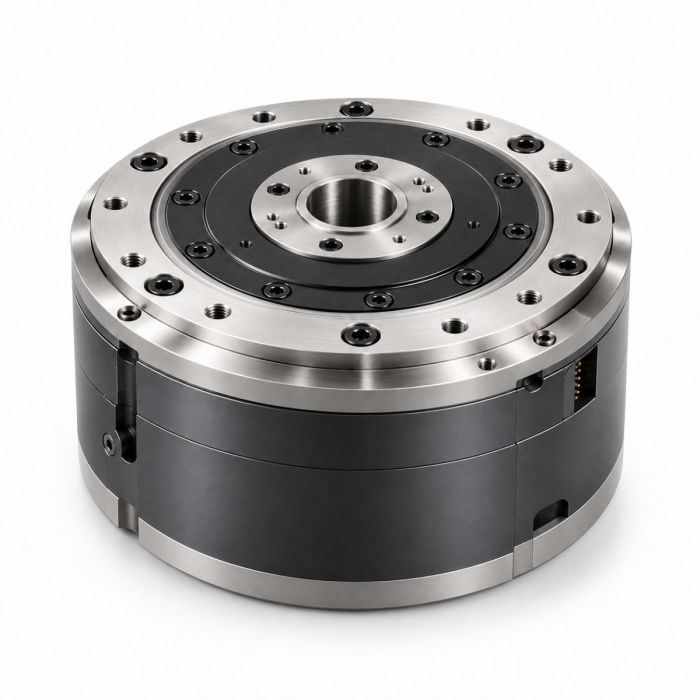
Most of what makes a humanoid robot difficult to build happens inside its joints, where a motor, gearing, position sensing and cooling all have to share a space no larger than a limb will allow. The Xynova PR21-100-140-HS Rotary Actuator answers that problem with an integrated module: a 48V joint that delivers 140Nm of peak torque, carries a 16bit encoder and repeats its position to within ≤0.1°, all inside a cylindrical body of Φ100×61.7mm. For engineers who have spent weeks assembling a joint from separate parts, a module of this kind changes where the effort goes, away from mechanical packaging and towards motion, control and the behaviour of the robot as a whole.
Robots Middle East supplies the Xynova PR21-100-140-HS Rotary Actuator to universities, research institutes, robotics start-ups and industrial integrators across the Middle East. Robots Middle East prepares each quotation, arranges delivery to the customer's site and supports the module after it arrives, so that a project team has one point of contact from the first specification question through to integration.
Background
Xynova and its focus on humanoid components
Xynova (曦诺未来) is a brand of 杭州曦诺未来科技有限公司, a company founded in December 2024 in Hangzhou, Zhejiang. Rather than building complete robots, the company concentrates on the core components that humanoid machines depend upon: high-degree-of-freedom dexterous hands and electric drive systems. That specialisation matters to buyers. A component maker that does not compete with its own customers on finished robots tends to design its modules for integration by others, and the Xynova rotary actuator range is presented in exactly that way, as a family of joints intended to be combined into a full humanoid body.
An integrated joint with its own software
The PR21-100-140-HS belongs to a range that covers 6.7-500Nm of torque, a span chosen to meet the demands of humanoid waist, hip, knee and elbow joints. Across the range, a compact structure houses a built-in high-speed heat dissipation channel that keeps the module running efficiently under load. Xynova also develops its own host-computer software and supplies rich API interfaces, so that several modules can be controlled in coordination. For a team building a multi-joint machine, that combination of hardware and software from one source reduces the number of interfaces that have to be reconciled before the first movement.
Technical Specifications
| Specification | Value |
|---|---|
| Rated voltage | 48V |
| No-load speed | 130r/min |
| Peak torque | 140Nm |
| Torque density | 117Nm/kg |
| Module weight | 1.2kg |
| Dimensions | Φ100×61.7mm |
| Encoder resolution | 16bit |
| Repeat positioning accuracy | ≤0.1° |
Specifications are as published by the manufacturer and are confirmed against the datasheet at quotation.
The manufacturer has not published the rated torque, the continuous torque, the rated current, the motor type, the backlash, the communication interface, the mounting dimensions, the IP rating, the operating temperature range or the contents of the box; Robots Middle East confirms these details at quotation.
What does a torque density of 117Nm/kg mean for a humanoid joint?
Torque density is the figure that tells an engineer how much turning force a joint provides for every kilogram it adds to the machine. The PR21-100-140-HS reaches 117Nm/kg, with a peak torque of 140Nm from a module weighing 1.2kg. In a humanoid robot, that ratio has consequences well beyond the joint itself. Every actuator placed in a limb is itself a load that the joints closer to the torso must lift and accelerate, so a lighter module for a given torque eases the burden on the whole kinematic chain.
The compact envelope supports the same goal. A body of Φ100×61.7mm is short along its axis, which helps when a joint must sit inside the profile of an arm or leg rather than protrude from it. Combined with the 16bit encoder and a repeat positioning accuracy of ≤0.1°, the module gives the control system fine feedback about where the joint is, which is what allows a walking or reaching robot to correct its posture smoothly rather than in coarse steps.
It is worth remembering that peak torque describes what a joint can deliver in short bursts, such as the push-off of a step or the start of a lift, rather than the load it holds for long periods. Sizing a joint for sustained poses therefore draws on the full datasheet, which forms part of every project discussion with Robots Middle East.
How does the PR21-100-140-HS fit within the Xynova rotary actuator range?
The Xynova family also includes the Xynova PR20-102-130-HS Rotary Actuator, the Xynova PR43-120-600-HB Rotary Actuator, the Xynova PR64-110-500 Rotary Actuator and the Xynova PRH19-57-25-HS Rotary Actuator. Together the family is designed to cover the joints of a complete humanoid body, from the waist and hips to the knees and elbows. The figures in this article belong to the PR21-100-140-HS alone; each sibling has its own datasheet, and its values should not be assumed from this one.
The practical advantage of a single family is consistency. Modules that share a design approach, a cooling concept and the same host-computer software can be brought together in one control architecture, which shortens the work of integrating a full robot. A team can select the joint that matches each position in the body and still manage all of them through one software environment.
Who is the Xynova PR21-100-140-HS Rotary Actuator for?
The first group is humanoid robot developers, whether in a corporate research department or a start-up, who need a ready-made joint with a strong torque-to-weight ratio and precise feedback. For these teams the module offers a way to move quickly from mechanical design to motion experiments.
The second group is universities and research institutes. Laboratories studying locomotion, manipulation or human-robot interaction benefit from a joint whose software and API allow several modules to be coordinated without writing low-level drivers from scratch, leaving students and researchers free to concentrate on the questions they are investigating.
The third group is system integrators and industrial prototyping teams building articulated mechanisms other than humanoids, such as custom arms or test fixtures, where an integrated rotary joint simplifies assembly.
Where a project needs a different balance of torque and size at a particular position in the robot, the other members of the family are the natural place to look, and Robots Middle East can advise on which module suits each joint. The complete selection is available in the Robot Actuators category.
What is the Xynova PR21-100-140-HS Rotary Actuator used for?
- Humanoid limb prototyping – a compact, integrated joint for arms and legs where every kilogram in the limb affects the rest of the robot.
- Multi-joint coordinated control – several modules managed together through Xynova's host-computer software and API interfaces.
- Locomotion research – experiments in balance and gait that depend on fine joint position feedback.
- Manipulation studies – reaching and grasping systems that need repeatable joint positioning.
- Teaching laboratories – university courses in mechatronics and control built around a ready-made actuator rather than a hand-assembled joint.
- Custom articulated mechanisms – integrator projects and test rigs that require a self-contained rotary joint.
Pricing and Availability
The Xynova PR21-100-140-HS Rotary Actuator is supplied on quotation, prepared by Robots Middle East for each project according to quantity and requirements. Delivery, customs and after-sales support are arranged together with the quotation. Teams planning several joints at once can request a single quotation covering the modules for each position in the robot. To begin, a request for a quotation for the Xynova PR21-100-140-HS Rotary Actuator is available on this page.
Frequently Asked Questions
What peak torque does the PR21-100-140-HS deliver?
The module delivers a peak torque of 140Nm at a rated voltage of 48V, with a no-load speed of 130r/min.
How heavy and how large is the module?
The module weighs 1.2kg and measures Φ100×61.7mm, giving a torque density of 117Nm/kg.
How precise is its positioning?
The actuator uses a 16bit encoder and achieves a repeat positioning accuracy of ≤0.1°.
Can several modules be controlled together?
Yes. Xynova develops its own host-computer software with rich API interfaces for the coordinated control of multiple modules.
How does the module manage heat?
The Xynova rotary actuator range uses a compact structure with a built-in high-speed heat dissipation channel, so that the modules run efficiently under load.
Which joints is the Xynova range designed for?
The range covers 6.7-500Nm of torque, sized for humanoid waist, hip, knee and elbow joints, so that a whole robot body can be equipped from one family.
Where can I buy the Xynova PR21-100-140-HS Rotary Actuator and what does it cost?
Robots Middle East supplies the module across the Middle East on quotation. The quotation is prepared for your project, with delivery, customs and support arranged alongside it.
Summary
The hardest part of a humanoid robot is fitting strength, sensing and cooling into joints that the rest of the machine can afford to carry. The Xynova PR21-100-140-HS Rotary Actuator addresses that directly: 140Nm of peak torque at a torque density of 117Nm/kg, a 16bit encoder with ≤0.1° repeatability, and a compact body supported by software for coordinated multi-joint control. It comes from a Hangzhou manufacturer that concentrates entirely on humanoid components, and it sits within a family designed to equip a complete robot. For teams across the region planning their next humanoid or articulated platform, this page is the starting point.