Xynova PR43-120-600-HB Rotary Actuator
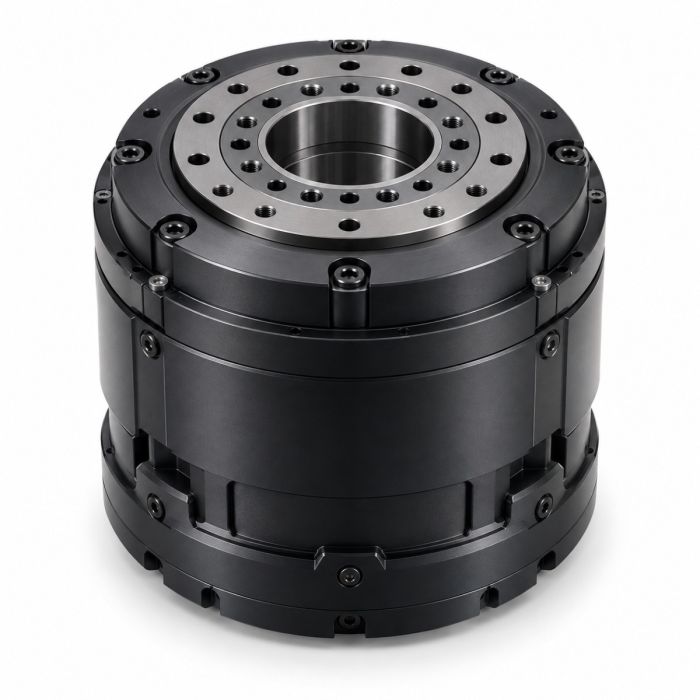
In stock
- BRAND:
- XYNOVA
- MODEL:
- PR43-120-600-HB
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-PR43-120-600-HB
Xynova PR43-120-600-HB Rotary Actuator
A sprinter and a marathon runner are both athletes, yet their legs are built for very different work. A humanoid robot asks its joints to be both at once: to hold a posture patiently, then to move in a sudden, forceful burst when it steps, recovers its balance or lifts a load. The Xynova PR43-120-600-HB Rotary Actuator is designed for that second moment. Its planetary gearbox was developed in-house and optimised for high-burst movements, and its torque density of 140Nm/kg means that strength does not come at the expense of mass carried around the robot’s frame.
Robots Middle East supplies the Xynova PR43-120-600-HB Rotary Actuator to universities, research institutes, robotics start-ups and system integrators across the Middle East. Robots Middle East prepares each quotation, arranges delivery to the project site and remains the point of contact for technical support once the actuators are installed.
Background
Xynova Technology Co., Ltd.
Xynova Technology Co., Ltd. is a core component supplier in the field of humanoid robots. Rather than building complete robots, the company concentrates on the parts that determine how a robot moves: the rotary and linear actuators that form its joints. That focus matters to buyers, because a humanoid platform is usually assembled from many identical or closely related joint modules, and a supplier that treats those modules as its central product tends to offer a coherent family rather than a single isolated part. The PR43-120-600-HB sits within such a family, alongside other rotary actuators and the Xynova linear actuators.
An in-house gearbox and an in-house software layer
Two elements of this actuator are developed by Xynova itself. The first is the planetary gearbox, optimised for high-burst movements: the short, intense demands for torque that walking, balancing and manipulation impose on a humanoid joint. The second is the upper-level software, which offers a rich set of API interfaces and enables easy coordination and control of multiple actuators. For anyone building a robot with many joints, the second point is as significant as the first. A single actuator can be tuned on a test bench; a full limb or a complete body requires every joint to be commanded together, and a manufacturer-supplied software layer designed for that task shortens the path from individual components to a working machine.
Technical Specifications
| Specification | Value |
|---|---|
| Model | PR43-120-600-HB |
| No-load speed | 32r/min |
| Torque density | 140Nm/kg |
| Size | Φ120×126mm |
| Gearbox | In-house developed planetary gearbox, optimised for high-burst movements |
| Software | In-house developed upper-level software with a rich set of API interfaces for coordinating and controlling multiple actuators |
| Intended use | Custom-designed for humanoid robots |
Specifications are as published by the manufacturer and are confirmed against the datasheet at quotation.
The manufacturer has not published the rated torque, rated current, backlash, communication interface, operating temperature, IP rating or the contents of the box; these are confirmed with you at quotation.
What sets the PR43-120-600-HB apart from a general-purpose servo?
Many rotary actuators on the market are general-purpose servos, designed for conveyors, positioning stages or industrial arms bolted to a floor. Such machines rarely need to carry their own actuators around, and they seldom face the abrupt load changes of a body in motion. The PR43-120-600-HB starts from a different brief: it is custom-designed for humanoid robots. That intention shows in each of its stated characteristics.
The planetary gearbox is not a bought-in unit but one Xynova developed itself, optimised for high-burst movements. In a humanoid, those bursts are the norm rather than the exception — a foot strike, a recovery step, a sudden lift — and a gearbox tuned for them is better matched to the task than one designed for steady, continuous rotation.
The software layer is the other point of difference. A general-purpose servo typically leaves the integrator to write the coordination logic for every joint. Xynova supplies upper-level software with a rich set of API interfaces that enables easy coordination and control of multiple actuators, which suits a robot where a dozen or more joints have to act as one.
Why does torque density matter in a humanoid joint?
In a walking robot, every actuator is also a load for the actuators beneath it. The joints of an ankle carry the knee, the knee carries the hip, and the hip carries the torso, arms and head. Each gram added high on the body has to be accelerated, decelerated and balanced by every joint below. Torque density — the torque an actuator delivers relative to its own mass — is therefore one of the most telling figures for this class of component.
The PR43-120-600-HB has a torque density of 140Nm/kg, within a body measuring Φ120×126mm. Together, those two figures describe an actuator that aims to deliver strength without forcing the designer to enlarge the limb around it or to strengthen the joints further down the kinematic chain. Its no-load speed of 32r/min completes the picture of a unit intended for forceful, controlled joint motion rather than high-speed spinning.
Who is the Xynova PR43-120-600-HB Rotary Actuator for?
The first group is humanoid robot developers, whether in a university laboratory, a corporate research centre or a start-up building its first full-size platform. The actuator was custom-designed for their machines, and the multi-actuator software supports the way they work: many joints, controlled together.
The second group is system integrators who assemble robots for clients and value a supplier whose actuators share a common software approach. Using one manufacturer’s family across a robot simplifies wiring, control and spare-parts planning.
The third group is academic teams teaching or researching locomotion, balance and whole-body control, for whom a ready-made software layer with documented APIs allows students to concentrate on algorithms rather than low-level drivers.
Not every joint in a robot needs the same actuator. Xynova offers other rotary actuators, including the Xynova PR64-110-500 Rotary Actuator, the Xynova PR20-102-130-HS Rotary Actuator, the Xynova PR21-100-140-HS Rotary Actuator and the Xynova PRH19-57-25-HS Rotary Actuator. Robots Middle East can advise on which model matches each joint of your design. The wider range is available in the Robot Actuators category.
What is the Xynova PR43-120-600-HB Rotary Actuator used for?
- Humanoid robot joints: the purpose for which the actuator was custom-designed.
- Dynamic motion research: studying walking, balance recovery and other movements that place burst demands on a joint.
- Multi-joint coordination: building limbs or full bodies controlled together through the manufacturer’s software and APIs.
- Prototype platforms: early-stage robots where a compact, torque-dense joint shortens the design cycle.
- Teaching and training: university courses on robot control that benefit from documented software interfaces.
- Component evaluation: benchmarking joint modules on a test rig before committing to a full robot build.
Pricing and Availability
The Xynova PR43-120-600-HB Rotary Actuator is supplied on quotation, so that quantities and configuration can be agreed for your project before an order is placed. Delivery, customs clearance and technical support are arranged by Robots Middle East together with the quotation. To begin, please tell us how many units you require and the robot or joint for which they are intended; the request form is available on this page.
Frequently Asked Questions
What type of gearbox does the PR43-120-600-HB use?
It uses a planetary gearbox developed in-house by Xynova and optimised for high-burst movements.
What is the torque density of this actuator?
The torque density is 140Nm/kg.
How large is the actuator?
The actuator measures Φ120×126mm.
What is its no-load speed?
The no-load speed is 32r/min.
Can several actuators be controlled together?
Yes. Xynova supplies in-house developed upper-level software with a rich set of API interfaces that enables easy coordination and control of multiple actuators.
What kind of robot is the actuator designed for?
It is custom-designed for humanoid robots, where joints must cope with sudden, high-burst movements.
Where can I buy the Xynova PR43-120-600-HB Rotary Actuator and what does it cost?
You can buy it from Robots Middle East, which supplies it across the Middle East. The cost depends on quantity and project requirements and is set out in a quotation, which you may request on this page.
Summary
A humanoid joint has to be ready for the burst as well as the long hold, and the Xynova PR43-120-600-HB Rotary Actuator is built with that sudden effort in mind. An in-house planetary gearbox optimised for high-burst movements, a torque density of 140Nm/kg in a Φ120×126mm body, and upper-level software designed to coordinate many actuators together make it a component conceived for humanoid robots from the outset. Robots Middle East supplies it with delivery and support across the region. For a robot that must move with both strength and agility, this page is the starting point.