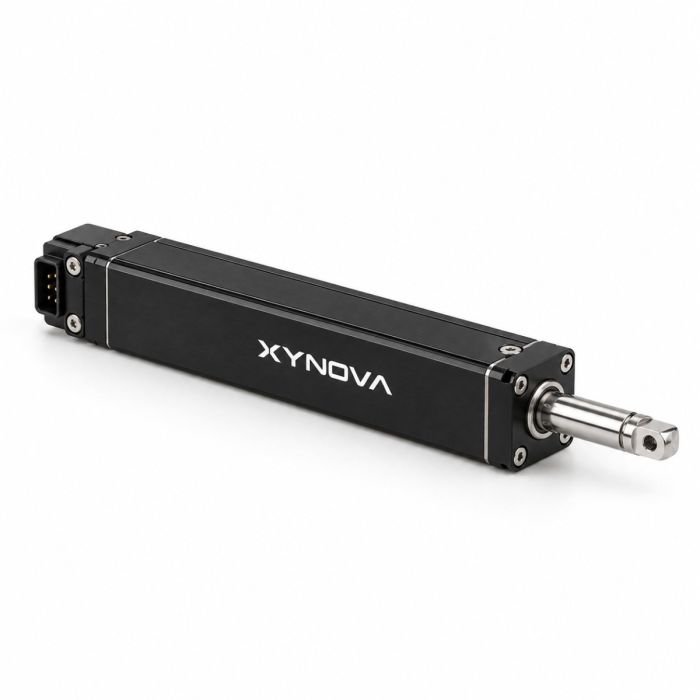
Xynova PRM10-20-34-150-F Linear Actuator
In stock
- BRAND:
- XYNOVA
- MODEL:
- PRM10-20-34-150-F
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-PRM10-20-34-150-F
Xynova PRM10-20-34-150-F Linear Actuator
In a humanoid robot, every gram carried at the end of a limb must be lifted by each joint behind it, so the actuators furthest from the torso are judged less by raw power than by how much useful work they deliver for their mass. The Xynova PRM10-20-34-150-F Linear Actuator meets that brief with a micro electric cylinder that combines a maximum thrust of ≥150N with a weight of ≤34g, giving a slender component a firm and repeatable push. An in-house planetary roller screw, joint self-locking and control software with a rich set of API interfaces make it a building block for engineers who must fit strength, precision and coordination into very little space.
Robots Middle East supplies the PRM10-20-34-150-F to universities, research laboratories, robotics start-ups and system integrators across the Middle East. Robots Middle East prepares each quotation, coordinates delivery to your site and remains your point of contact for technical support once the actuator has arrived, so that projects in the region can source Xynova components through a single, accountable partner.
Background
Xynova Technology Co., Ltd. and its focus on humanoid robots
Xynova Technology Co., Ltd. is a core component supplier in the field of humanoid robots. Rather than assembling actuators from bought-in parts, the company develops the critical elements itself: the micro planetary roller screw, the frameless torque motor or brushless hollow cup motor, and the upper-level software that coordinates several modules at once. Its portfolio pairs linear actuators such as this one with rotary actuators and a dexterous hand series, so that a development team can build a complete electric drive train from one manufacturer and have it customised to the needs of the robot.
This vertical approach matters in humanoid robotics, where joints are densely packed, cable routes are short and every component has to cooperate with its neighbours. A supplier that controls the motor, the transmission and the software can tune them as a set, which tends to simplify integration for the engineers who build on its modules.
A planetary roller screw at micro scale
At the heart of the PRM10-20-34-150-F sits an in-house developed 7mm micro planetary roller screw, which greatly improves transmission efficiency and suits a wide range of industrial and everyday applications. In general engineering practice, a planetary roller screw spreads the load across several threaded rollers arranged around a central screw, rather than relying on a single row of contact points. That arrangement is valued wherever high axial force must be transmitted through a compact mechanism, which is precisely the situation inside a robotic hand or limb.
The screw is driven by an in-house developed frameless torque motor or brushless hollow cup motor, providing higher torque, longer lifespan and quieter operation. Together, motor and screw convert rotation into the controlled linear stroke that a tendon-like joint mechanism requires.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Micro electric cylinder designed for humanoid robots |
| Effective stroke | 19+1%mm |
| Size (L×W×H) | 10*13.5*81mm |
| No-load max speed | ≥34mm/s |
| Full-load speed | ≥9mm/s |
| Max thrust | ≥150N |
| Weight | ≤34g |
| Operating voltage | DC12±10%V |
| Repeatability | ±0.04mm |
| Operating temperature | -15~60℃ |
| Static current | 0.05A |
| No-load current | 0.4A |
| Roller screw | In-house developed 7mm micro planetary roller screw |
| Motor | In-house developed frameless torque motor/brushless hollow cup motor |
| Self-locking | Easy joint self-locking |
Specifications are as published by the manufacturer and are confirmed against the datasheet at quotation.
The manufacturer has not published the IP rating, communication interface, feedback sensor type, package contents, stall current, service life, noise level or mounting method; Robots Middle East confirms these points at quotation.
What do the speed and current figures tell a robot designer?
Two speeds are listed for this actuator, and the distance between them is instructive. Without load, the cylinder travels at ≥34mm/s; at full load, it still moves at ≥9mm/s. For a designer, this describes the working envelope of a joint: quick repositioning when a finger closes on nothing, and slower, deliberate travel when the mechanism presses against an object at the upper end of its ≥150N thrust. Motion planning can be built around those two points, with grasp speed tapered as contact force rises.
The electrical figures complete the picture. The actuator runs on DC12±10%V, draws 0.4A without load and only 0.05A when static. In a robot hand with many actuators sharing one supply, a low static draw is a meaningful advantage, because many joints spend much of their time holding a pose rather than moving. Joint self-locking reinforces this: a power failure poses no risk to the joint, which enhances safety during operation and protects both the mechanism and the object it holds.
Precision rounds off the profile. A repeatability of ±0.04mm across an effective stroke of 19+1%mm means the actuator returns reliably to the same position, which is what calibrated grasps, repeated test cycles and learning-based control routines depend upon.
How does the PRM10-20-34-150-F work with other Xynova modules?
The PRM10-20-34-150-F is designed to be paired with Xynova rotary actuators and the dexterous hand series, offering fully customised electric drive solutions. In practical terms, a humanoid project can combine linear actuators for finger or wrist linkages with rotary actuators for larger joints, all from the same supplier.
Coordination is handled by Xynova's in-house developed upper-level software, which provides a rich set of API interfaces and enables easy coordination and control of multiple modules. For research teams, this shortens the path from bench test to multi-joint demonstration, as several actuators can be commanded from one software environment rather than through separate tools. The physical interface and wiring details are among the points that Robots Middle East settles with you during quotation.
Who is the Xynova PRM10-20-34-150-F Linear Actuator for?
The first audience is humanoid robot developers who need force at the extremities without adding mass that the rest of the body must carry. Teams building dexterous hands form a second group: the combination of compact dimensions, ≥150N thrust and ±0.04mm repeatability addresses the core demands of finger and thumb actuation.
University laboratories and research institutes are a third segment. Projects in manipulation, prosthetics research and embodied artificial intelligence benefit from a component whose behaviour is documented and repeatable, and whose software exposes an API for experimentation. System integrators who assemble bespoke electric drive trains for clients form the fourth group, particularly where linear and rotary motion must be orchestrated together.
The PRM10 series includes several versions, among them the Xynova PRM10-20-18-200-F Linear Actuator. Where your design calls for a different balance of speed and thrust, Robots Middle East can place the relevant datasheets side by side in the quotation so that you select the version that suits your joint. Further options are available in our Robot Actuators category.
What is the Xynova PRM10-20-34-150-F Linear Actuator used for?
- Humanoid finger actuation — driving tendon or linkage mechanisms that open and close individual fingers.
- Wrist and forearm linkages — providing compact linear force for small joints near the end of a robotic arm.
- Dexterous hand prototypes — forming part of a complete hand alongside Xynova's dexterous hand series and rotary actuators.
- Research and teaching platforms — supporting university work on grasping, manipulation and control algorithms.
- Multi-module drive systems — operating as one coordinated element among several modules through the upper-level software API.
- Compact automation mechanisms — supplying precise linear motion in industrial and everyday devices where space is limited.
Pricing and Availability
Robots Middle East supplies the Xynova PRM10-20-34-150-F Linear Actuator on a quotation basis, so that each offer reflects your quantity, your application and the configuration you require. When requesting a quotation, please tell us how many units you need, the robot or mechanism they will drive, and any questions about the specifications that the manufacturer has not yet published. Delivery, customs and support are arranged with the quotation. To begin, the quotation request form is available on this page.
Frequently Asked Questions
What thrust does the PRM10-20-34-150-F deliver?
The actuator delivers a maximum thrust of ≥150N. At full load it maintains a speed of ≥9mm/s.
What power supply does it require?
It operates on DC12±10%V. It draws 0.4A without load and 0.05A when static.
How precise is the actuator?
Its repeatability is ±0.04mm over an effective stroke of 19+1%mm. This makes it suitable for calibrated, repeated movements in robotic hands and joints.
What happens to the joint if power is lost?
The actuator features easy joint self-locking, so a power failure poses no risk to the joint. This enhances safety during operation.
In what temperature range can it operate?
The operating temperature range is -15~60℃. Robots Middle East can advise on suitability for your specific environment as part of the quotation.
Can it be controlled together with other Xynova modules?
Yes. Xynova's in-house upper-level software offers a rich set of API interfaces for coordinating multiple modules, and the actuator is designed to be paired with Xynova rotary actuators and the dexterous hand series.
Where can I buy the Xynova PRM10-20-34-150-F Linear Actuator and what does it cost?
You can purchase it from Robots Middle East, which supplies customers across the Middle East. The cost depends on quantity and configuration and is stated in a quotation prepared for your project.
Summary
The further an actuator sits from the body of a humanoid robot, the more its mass counts against it, and the Xynova PRM10-20-34-150-F Linear Actuator is built around that reality. It pairs ≥150N of thrust with a weight of ≤34g, holds its position through joint self-locking, draws little current at rest and returns to position with ±0.04mm repeatability. Its in-house roller screw, motor and software make it part of a coordinated Xynova drive system rather than an isolated part. For teams in the region who want to put that force-to-mass balance to work in a hand, wrist or compact mechanism, with Robots Middle East handling quotation, delivery and support, this page is the starting point.