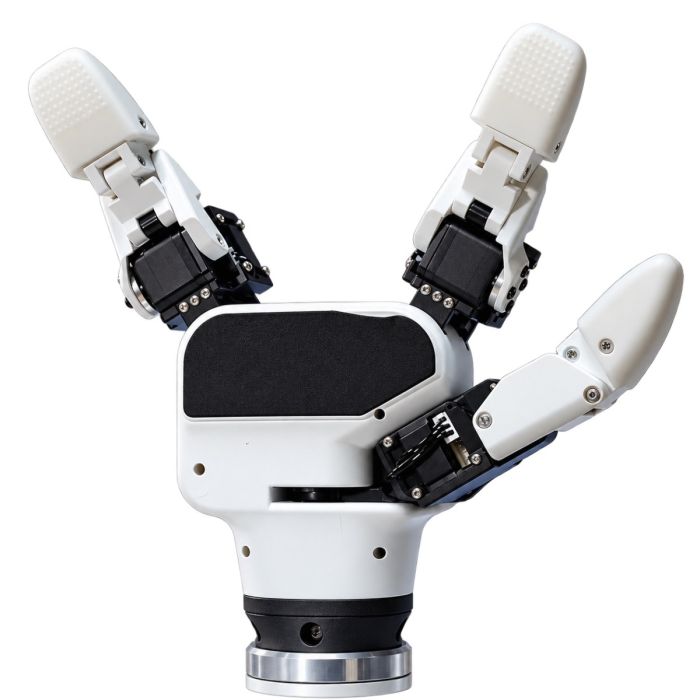
Elephant Robotics myGripper H100 Right Hand (4010700100)
In stock
- BRAND:
- ELEPHANT ROBOTICS
- MODEL:
- myGripper H100
- PART #:
- 4010700100
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Elephant Robotics Technology-4010700100
Elephant Robotics myGripper H100 Right Hand (4010700100)
Most end effectors are judged by what they leave behind: the part moved, the sample placed, the box stacked. In a research laboratory, the more valuable output is often the record of how the grasp unfolded: which joint moved first, how torque built as the fingers closed, and where each position finally settled. The Elephant Robotics myGripper H100 Right Hand (4010700100) is built around that second kind of output. It is a three-finger dexterous hand whose six digital servo motors can be commanded for torque, speed and absolute position, and it reports its status at 100Hz while it works, so every grasp becomes a data set as well as an action.
Robots Middle East supplies the myGripper H100 Right Hand to universities, research institutes, technical colleges and robotics developers across the Middle East. Robots Middle East prepares each quotation to suit the customer's project, arranges delivery to the laboratory or campus, and remains the point of contact for technical questions once the hand is in service, whether the team is integrating it into an existing robot cell or building a teaching programme around it.
Background
Elephant Robotics and its developer heritage
The myGripper H100 is developed by Shenzhen Elephant Robot Technology Co., Ltd., the company behind the Elephant Robotics brand. Elephant Robotics is best known for compact collaborative and desktop robot arms aimed at education, research and light automation, and its products have a reputation for being approachable to programme. The myGripper H100 extends that thinking from the arm to the hand: rather than a closed tool that simply opens and closes, it is a device intended to be programmed, studied and modified. Customers who wish to see the wider family can browse the Elephant range.
A hand designed for measurement
The key technology in the H100 is its combination of individually controlled servo joints with an open, documented communication path. Each of the six movable joints is driven by its own high-performance digital servo motor, and the hand accepts commands for output torque, motion speed and absolute position. Communication runs over RS485 using the MODBUS protocol, and the hand supports high-frequency 100Hz communication for real-time status monitoring during grasping. On-board control is handled by an ESP32 chip with Wi-Fi and dual-mode Bluetooth. On the software side, a Python driver library is installable via PyPI, and the hand is compatible with ROS1 and ROS2, including RVIZ simulation support for displaying state and collecting real-time data. For a research group, that means the hand fits into tooling the team very likely uses already.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Three-finger dexterous robotic hand |
| Version | Right Hand (4010700100) |
| Number of fingers | 3 fingers (corresponding to the human thumb, index finger and ring finger) |
| Movable joints | 6 |
| Servo motors | 6 high-performance digital servo motors |
| Controllable parameters | Output torque, motion speed, absolute position |
| Payload | 500g |
| Self-weight | 780g |
| Stroke (diameter) | 0 – 130mm |
| Motion speed | 60 degrees per second per joint |
| Communication frequency | 100Hz |
| Lifespan | 1,000,000 cycles or more |
| Power parameters | 24V, 2A |
| Electrical interface | M8 Pin aviation connector |
| Communication interface | RS485 |
| Protocol type | MODBUS |
| Main control chip | ESP32 |
| Main control parameters | 240MHz dual-core, 600 DMIPS, 520KB SRAM, Wi-Fi, dual-mode Bluetooth |
| Software support | Python driver library via PyPI; ROS1 and ROS2; RVIZ simulation |
| Fixing method | Screw fixing |
Specifications are as published by the manufacturer and are confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the IP rating, the operating temperature range, the gripping force or the noise level of the hand; these are confirmed at quotation.
What makes a three-finger dexterous hand different from a parallel gripper?
A parallel or adaptive gripper reduces grasping to a single question: how far apart should the jaws be? That is ideal for repetitive pick-and-place, but it hides almost everything a researcher wants to examine. The myGripper H100 distributes the task across three fingers arranged like a human thumb, index finger and ring finger, with six movable joints between them. The thumb can oppose the other two fingers, the fingers can wrap around rounded objects, and the hand can form postures that a two-jaw tool cannot.
Because each joint is driven by its own digital servo and can be set by torque, speed or absolute position, the experimenter decides how the hand behaves rather than accepting a fixed closing profile. A soft object can be approached at low torque; a demonstration can be slowed to make each joint's movement visible to students; a learning algorithm can be given direct control of every degree of freedom. The 100Hz status feed then turns each attempt into time-stamped joint data, which is exactly what grasp-planning, imitation-learning and teleoperation studies need. The trade-off is complexity: a dexterous hand asks more of its programmer than a simple gripper, which is why the Python library, the ROS1 and ROS2 compatibility and the RVIZ simulation support matter so much.
Should I choose the Right Hand, the Left Hand or the pair?
The myGripper H100 is offered in three versions: the Right Hand described on this page, the Elephant Robotics myGripper H100 Left Hand (4010700101), and the Elephant Robotics myGripper H100 Left + Right Hand (4010700098) set. The choice follows the robot it will be fitted to and the research question. A single-arm cell, or a project that mirrors human right-hand demonstrations, is naturally served by the Right Hand. A team studying bimanual manipulation, handovers between hands or humanoid-style tasks will be better served by the paired set, so that both sides share the same hardware and the same control interface. Robots Middle East can advise on which configuration suits a given setup when the quotation is prepared.
Who is the myGripper H100 Right Hand for?
The first group is university and institute laboratories working on manipulation, grasp planning, tactile and force-aware control, or machine learning for robotics. For them, the combination of per-joint control and real-time data capture is the central attraction, and ROS compatibility shortens the path from unboxing to the first experiment.
The second group is educators. Technical colleges and university departments teaching robotics, mechatronics or programming can use the hand to show how kinematics, servo control and communication protocols work together in one visible device. The Python driver lowers the threshold for students, while MODBUS over RS485 gives more advanced classes a real industrial protocol to work with.
The third group is developers and integrators building prototypes: service-robot concepts, demonstrators for exhibitions, or proof-of-concept cells where a hand-like grasp communicates the idea better than a conventional gripper. Those assembling a complete platform may also wish to review the collaborative arms in our Cobots category. Teams whose research involves two-handed tasks should look at the paired version mentioned above rather than buying two single hands separately.
What is the myGripper H100 Right Hand used for?
- Grasp research: studying how different finger postures and torque settings affect a stable hold on varied objects.
- Data collection for learning: recording joint states at 100Hz to train and evaluate grasping or imitation-learning models.
- Robotics teaching: demonstrating servo control, kinematics and serial communication to students on a single device.
- Simulation and validation: comparing behaviour in RVIZ with the physical hand under ROS1 or ROS2.
- Teleoperation studies: mapping human hand movements onto the thumb, index and ring fingers of the hand.
- Demonstrators and prototypes: showing hand-like manipulation in exhibitions, laboratories and concept robots.
Pricing and Availability
The myGripper H100 Right Hand is supplied on quotation, so that the offer reflects the configuration, quantity and any accompanying equipment the project requires. Delivery, customs clearance and after-sales support are arranged together with the quotation by Robots Middle East. To receive an offer for your laboratory, institution or company, please use the quotation request available on this page.
Frequently Asked Questions
How many fingers and joints does the myGripper H100 have?
It has three fingers, corresponding to the human thumb, index finger and ring finger, with six movable joints driven by six digital servo motors.
What payload can the hand handle?
The payload is 500g, and the hand itself weighs 780g.
How does the hand communicate with a controller?
It uses an RS485 communication interface with the MODBUS protocol, connected through an M8 Pin aviation connector, and supports 100Hz communication for real-time status monitoring.
Which software environments are supported?
A Python driver library is installable via PyPI, and the hand is compatible with ROS1 and ROS2, including RVIZ simulation support.
What power supply does it require?
The power parameters are 24V, 2A.
How is the hand mounted?
The hand is attached by screw fixing; the mounting arrangement for a specific robot arm is confirmed with Robots Middle East at quotation.
Where can I buy the Elephant Robotics myGripper H100 Right Hand and what does it cost?
You can buy it from Robots Middle East, which supplies it across the Middle East. The cost depends on the configuration and quantity, so please request a quotation on this page and we will prepare an offer for you.
Summary
A conventional gripper finishes its job when the object is held; the myGripper H100 Right Hand begins its most useful work at that moment, because it records how the hold was achieved. Three fingers, six servo-driven joints, control over torque, speed and position, and a 100Hz status feed over RS485 and MODBUS make it a tool for understanding grasping, not merely performing it. With Python, ROS1, ROS2 and RVIZ support, it fits into the workflows of research groups and teaching departments alike, and Robots Middle East handles quotation, delivery and support across the region. For laboratories and classrooms ready to treat every grasp as an experiment, this page is the starting point.