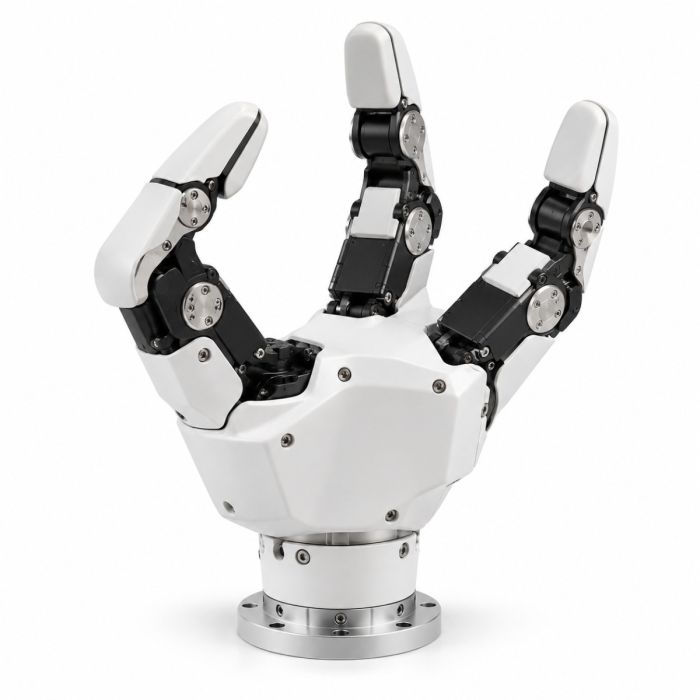
Elephant Robotics myGripper H100 Left Hand (4010700101)
In stock
- BRAND:
- ELEPHANT ROBOTICS
- MODEL:
- myGripper H100
- PART #:
- 4010700101
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Elephant Robotics Technology-4010700101
Elephant Robotics myGripper H100 Left Hand (4010700101)
Ask a person to open a jar and both hands go to work: one holds, the other turns. Robotics laboratories that try to reproduce this kind of coordinated manipulation soon find that a single end effector tells only half the story, and the missing half is very often the left. The Elephant Robotics myGripper H100 Left Hand (4010700101) fills that place. It is a three-finger dexterous hand whose fingers correspond to the human thumb, index finger and ring finger. Six servo-driven joints move it, and it is commanded over RS485 using the MODBUS protocol. It is built for researchers and teachers who want a robot to hold objects in the way people do, not merely to clamp them.
Robots Middle East supplies the myGripper H100 Left Hand to universities, research centres, technical colleges and engineering teams across the Middle East. Robots Middle East prepares each quotation, arranges delivery to the customer's site and remains the point of contact for technical questions once the hand is in service. A laboratory therefore deals with one partner from the first enquiry to the first successful grasp.
Background
Elephant Robotics and its lineage
Elephant Robotics is a Shenzhen-based manufacturer best known for compact collaborative and desktop robot arms, including the myCobot family that has found a place in many teaching laboratories and makerspaces. Over time its range has grown beyond arms to include the end effectors, vision kits and accessories that turn an arm into a complete working cell; the wider line-up is gathered in the Elephant category. The myGripper H100 belongs to this second wave of products. Rather than adding another parallel gripper to the catalogue, the company developed a dexterous robotic hand designed specifically for robotics research, education and related scenarios.
Positioning: a hand with its own controller
What separates the H100 from a simple jaw gripper is where the intelligence sits. Each of its six movable joints is driven by a high-performance digital servo motor. The servos support current, position and speed control, so output torque, motion speed and absolute position can each be set for every movement. An ESP32 main control chip coordinates the hand: a 240MHz dual-core processor rated at 600 DMIPS, with 520KB SRAM, Wi-Fi and dual-mode Bluetooth. Towards the outside world the hand presents an industrial interface: an M8 Pin aviation connector, a 24V, 2A power supply and an RS485 line that speaks MODBUS, a protocol already understood by a great deal of automation equipment.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Three-finger dexterous robotic hand for robotics research, education and related scenarios |
| Number of fingers | 3 fingers (corresponding to the human thumb, index finger, and ring finger) |
| Movable joints | 6 |
| Payload | 500g |
| Self-weight | 780g |
| Stroke (diameter) | 0 – 130mm |
| Motion speed | 60 degrees per second per joint |
| Motor type | Servo motor supporting current, position, and speed control |
| Servo motors | 6 high-performance digital servo motors; control of output torque, motion speed and absolute position |
| Lifespan | 1,000,000 cycles or more |
| Electrical interface | M8 Pin aviation connector |
| Power parameters | 24V, 2A |
| Communication interface | RS485 |
| Protocol type | MODBUS |
| Main control chip | ESP32 |
| Main control parameters | 240MHz dual-core, 600 DMIPS, 520KB SRAM, Wi-Fi, dual-mode Bluetooth |
| Software | Compatible with ROS1 and ROS2; RVIZ simulation environment supported |
| Driver library | Standardised robot driver library, downloadable and installable via PyPI |
Specifications are as published by the manufacturer and are confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the IP rating, the gripping force, the operating temperature, the operating voltage range or the packaged weight of the left-hand unit; Robots Middle East confirms these at quotation.
Why choose the left-hand version of the myGripper H100?
The H100 is offered in three forms: a Left Hand, a Right Hand and a Left+Right Hand set. The choice is more than cosmetic. A hand whose fingers follow a human thumb, index finger and ring finger has a handedness of its own. The left-hand unit is the one to specify when the robot must take the role of a person's left hand. Typical cases include holding a workpiece steady while another tool works on it, reproducing the movements of a left-handed demonstrator, or completing a two-armed rig in which a right hand is already installed.
For a laboratory that already owns a right hand, the left unit supplies the second half of a bimanual set-up without duplicating equipment. For a group starting from scratch with a single arm, the decision usually follows the task. It depends on which side of the workpiece the arm stands, and which hand the human operators being studied or imitated would naturally use. Robots Middle East is glad to discuss these layout questions while preparing the quotation, so that the version ordered matches the cell it will work in.
How does the myGripper H100 integrate with a robot and its software?
Integration takes place at two levels. At the electrical level, the hand takes a 24V, 2A supply through an M8 Pin aviation connector, and commands travel over RS485 using MODBUS. RS485 and MODBUS form a long-established fieldbus pairing, so integrators who already work with controllers, industrial PCs or single-board computers will find the wiring and addressing familiar rather than proprietary.
At the software level, Elephant Robotics provides a standardised robot driver library that is downloaded and installed via PyPI, the Python package index. The hand is compatible with both ROS1 and ROS2 and supports the RVIZ simulation environment, where users can display the state of the robot and collect real-time data. A research group can therefore visualise grasps, log joint behaviour and refine control strategies within the toolchain it already uses for its arms. Because each joint accepts current, position and speed control, experiments can move from simple position commands to torque-aware grasping without changing hardware.
Who is the myGripper H100 Left Hand for?
The first audience is the research laboratory. Groups working on dexterous manipulation, bimanual coordination, grasp planning or learning from human demonstration need a hand that behaves like a hand, with independently controlled joints and a finger layout modelled on human anatomy. The left-hand version suits projects in which the robot takes the supporting or holding role, or in which two arms must work together.
The second audience is education. Universities and technical colleges teaching robotics, mechatronics or automation can use the H100 to show students servo control, fieldbus communication and ROS integration on a single, tangible device. Its support for ROS1 and ROS2 means it fits into courses built on either generation of the framework.
A third audience is developers and integrators who prototype handling concepts, as well as innovation centres that use robots for public demonstrations, where a hand making recognisable gestures draws more attention than a two-jaw gripper.
Not every buyer needs the left side. A single-arm cell in which the robot imitates a right-handed operator is better served by the Elephant Robotics myGripper H100 Right Hand (4010700100). Teams that intend to build a two-handed system from the outset should consider the Elephant Robotics myGripper H100 Left + Right Hand (4010700098), which brings both sides together in one order.
What is the myGripper H100 Left Hand used for?
- Bimanual manipulation research: paired with a right hand, it allows coordinated two-handed tasks to be studied on real hardware.
- Grasp planning and data collection: joint states can be displayed and recorded in RVIZ through ROS1 or ROS2 for analysis.
- Robotics teaching: students practise servo control, MODBUS communication and ROS integration on a genuine dexterous hand.
- Imitation and teleoperation studies: its thumb, index and ring finger layout makes mapping human hand motion onto the robot more intuitive.
- Laboratory object handling: it picks up and holds light items within its 500g payload for test and demonstration routines.
- Exhibitions and demonstrations: six movable joints allow expressive, hand-like gestures that explain robotics to visitors.
Pricing and Availability
Robots Middle East offers the myGripper H100 Left Hand by quotation, so that each offer reflects the configuration, the quantity and any arms or accessories a project requires. Delivery, customs clearance and technical support are arranged together with the quotation. To begin, please send your requirements through the quotation request available on this page.
Frequently Asked Questions
Is the Left Hand a different product from the Right Hand?
It is the left-handed version of the myGripper H100. Elephant Robotics also offers a Right Hand and a Left+Right Hand set, and the version should be chosen according to the role the hand will play in the cell.
Which software environments does the myGripper H100 support?
The hand is compatible with ROS1 and ROS2 and supports the RVIZ simulation environment for displaying its state and collecting real-time data. A standardised driver library is installed via PyPI.
How is the hand powered and controlled?
It takes a 24V, 2A supply through an M8 Pin aviation connector and communicates over RS485 using the MODBUS protocol. An ESP32 main control chip coordinates its six servo motors.
How much can the myGripper H100 hold?
The payload is 500g, and the hand itself weighs 780g. Its stroke, measured as a diameter, runs from 0 to 130mm.
How durable is the hand?
Elephant Robotics gives a lifespan of 1,000,000 cycles or more, which suits repeated experiments and daily classroom use.
Which robot arms can the hand be mounted on?
The sources for this page do not list compatible arms or mounting details. Robots Middle East confirms compatibility with your specific arm, including flange and wiring, as part of the quotation.
Where can I buy the Elephant Robotics myGripper H100 Left Hand (4010700101) and what does it cost?
You can obtain it from Robots Middle East, which supplies customers across the Middle East. The cost is provided in a quotation prepared for your project, which you can request on this page.
Summary
A jar is opened by two hands, and a robot that is to learn from people needs both sides as well. The myGripper H100 Left Hand provides the side that many laboratories lack. It combines three human-like fingers and six servo-driven joints with current, position and speed control, an ESP32 controller and an RS485 MODBUS interface, supported by ROS1, ROS2, RVIZ and a driver library installed via PyPI. Whether it completes an existing right-handed set-up, anchors a new bimanual project or brings dexterous grasping into the classroom, Robots Middle East handles the quotation, delivery and support. For any team ready to give its robot a left hand, this page is the starting point.